 Modbus Integration Guide
Read and write coils and registers on Modbus TCP, RTU and ASCII devices such as PLCs, drives and meters.
- Protocol
- Modbus TCP · RTU · ASCII
- Default port
- 502 (TCP)
- Operations
- FC01-FC06 · FC15-FC16
- Triggers
- Poll trigger
Communicate with PLCs, drives, meters, and sensors using MaestroHub's Modbus connector. This guide explains connection options, function authoring, pipeline usage, and advanced tuning for reliable operations.
Overview
With the Modbus connector you gain:
- Support for TCP, RTU, and ASCII transports through a single configuration model
- Reusable read/write functions covering coils, discrete inputs, holding registers, and input registers (FC01-FC06, FC15-FC16)
- Rich data type support:
raw,int16,uint16,int32,uint32,float32,int64,uint64,float64,bool,string,hex, andbits - Configurable byte order per function (
ABCD,CDAB,BADC,DCBA) for devices that store numbers low word first or byte-swapped - Connection diagnostics including retries, timeouts, health checks, and automatic reconnection
- Quick Add for bulk function creation via table entry or CSV import
Connection Configuration
Creating a Modbus Connection
Navigate to Connections → New Connection → Modbus and configure the following settings. The form is organized into five tabs: Connection, Transport, Advanced, Functions, and Health.
1. Profile Information
| Field | Default | Description |
|---|---|---|
| Profile Name | - | A descriptive name for this connection profile (required, max 100 characters). Must be unique across all connections. |
| Description | - | Optional description for this Modbus connection |
2. Connection Mode Settings
| Field | Default | Description |
|---|---|---|
| Transport Mode | tcp | Modbus communication protocol: TCP (Ethernet), RTU (Serial Binary), or ASCII (Serial Text): required |
| Unit ID | 1 | Modbus slave unit identifier (0-247) |
3. TCP Transport Settings
(Only displayed when Transport Mode = TCP)
| Field | Default | Description |
|---|---|---|
| IP Address:Port | localhost:502 | Target device address in host:port format (standard Modbus TCP port is 502): required |
| Connect Timeout | 3s | Maximum time to wait for the TCP connection to open (up to 1 minute). Requests after that use the Request Timeout. TCP keep-alive is always on, with the operating system's settings. |
| Gateway Serial Port | empty | For a gateway with several serial ports behind one address: the port this slave is wired to (letters, digits, _, ., -, up to 32). Connections with the same address and port take turns; leave it empty when one serial bus is behind the address. See Many slaves behind one gateway. |
4. Serial Transport Settings
(Only displayed when Transport Mode = RTU or ASCII)
| Field | Default | Description |
|---|---|---|
| Serial Device | /dev/ttyUSB0 | Serial port device path (e.g., /dev/ttyUSB0 on Linux, COM3 on Windows): required |
| Baud Rate | 9600 | Serial communication speed (1200/2400/4800/9600/19200/38400/57600/115200): required |
| Data Bits | 8 | Number of data bits per character (7 or 8): required |
| Parity | N (None) | Error detection method (N=None / E=Even / O=Odd): required |
| Stop Bits | 1 | Number of stop bits per character (1 or 2): required |
| RS-485 Mode | false | Enable RS-485 transceiver mode (direction control), in RTU and ASCII mode. Uses the Linux serial driver's RS-485 support; ignored on Windows. |
The defaults are the same in RTU and ASCII mode. Many ASCII devices use 7 data bits with Even parity (7E1); for those, set Data Bits to 7 and Parity to E yourself.
5. Advanced Settings
The Advanced tab contains timeout, retry, and Read Group options:
5a. Timeout & Retry Configuration
| Field | Default | Description |
|---|---|---|
| Request Timeout | 5s | Maximum time to wait for a Modbus response (0s to 1m). On RTU and ASCII this is also the serial read timeout. |
| Idle Timeout | 10s | Close connection after idle period (0s to 10m; 0s = never) |
| Retry Count | 2 | Number of retries on communication failure (0-10) |
| Retry Delay | 500ms | Delay between retry attempts (0s to 1m) |
5b. Serial Timing
The RTU inter-frame and inter-character delays are derived from the baud rate, as the Modbus serial specification defines them; there is nothing to set.
5c. Read Group Optimization
The Modbus Read Group node running in parallel execution mode coalesces adjacent register reads into a single broader Modbus request to reduce TCP roundtrips. This setting lets you tune how aggressively that batching happens for this specific connection.
| Field | Default | Description |
|---|---|---|
| Coalesce Max Register Gap | (empty: uses global default 0) | Maximum number of unmapped registers the executor may request between two adjacent functions in order to merge them into one Modbus request (0-125). Higher values reduce roundtrips but require those in-between registers to be mapped on the slave. |
How it works
Suppose you have three Read Holding Register functions at addresses 100, 102, and 108, each reading 2 registers. With coalesceMaxGap = 0 they are merged only when strictly adjacent (100+102 → one request) and 108 becomes a separate request. With coalesceMaxGap = 6 all three merge into a single ReadHolding(100, 10) request, but the executor now also asks the slave for registers 104–107, which must be mapped on that device.
Choosing a value
0(default, safe): The executor never requests a register you didn't configure. Works on every Modbus slave, including those with sparse register maps. Still reduces requests significantly when functions cover contiguous addresses.1–4: Tolerates small alignment padding between measurement groups. Works on most well-documented industrial meters and PLCs.5–10: Aggressive batching. Recommended only when you have verified from the device's register map documentation that all registers in the gap range are addressable (even if reserved/zero).- Higher values: Use only with intimate knowledge of the device's address space. The Modbus protocol limit is 125 registers per request.
Symptom of a value that's too high
If you see every function in a Read Group return modbus: exception '2' (illegal data address) (including functions whose individual read works fine when tested in isolation), your gap is exceeding what the slave will accept. Modbus slaves reject the entire coalesced read when any register in the requested range is unmapped, so a single hole anywhere in the merged span fails every function in that batch. Lower this setting (or set it to 0) until the errors disappear.
6. Health Check Configuration
These settings choose the probe the connection's health check sends. How often it runs, and how long it may take, is set by the platform's connection health checks, not per connection.
6a. Health Check Method
| Field | Default | Description |
|---|---|---|
| Health Check Method | status | Status sends the smallest Modbus request (read one coil at address 0); any answer, even a Modbus exception, counts as reachable. Read reads the register range you choose. |
6b. Read Method Fields
(Only displayed when Health Check Method = Read)
| Field | Default | Description |
|---|---|---|
| Register Type | holding | Type of register/coil to read: coil (FC01), discrete (FC02), holding (FC03), or input (FC04): required |
| Address | 0 | Starting address to read (0-65,535): required |
| Quantity | 1 | Number of registers/coils to read (1-2,000 for coils/discrete; 1-125 for registers): required |
7. Connection Labels
| Field | Default | Description |
|---|---|---|
| Labels | - | Key-value pairs to categorize and organize this Modbus connection (max 10 labels) |
Example Labels
environment: production: Deployment environmentline: line-1: Production lineequipment: plc: Equipment typelocation: factory-floor: Physical location
- Fields marked as "required" must be filled out before creating or saving the connection.
- TCP and Serial settings are mutually exclusive based on the selected Transport Mode.
- Every time value is a duration with its unit (
500ms,5s,1m). A bare number is refused. - The form includes real-time validation for all required fields.
- Selecting ASCII mode does not change Data Bits or Parity; set them to match the device (for example
7/Efor 7E1).
Function Builder
Creating Modbus Functions
After the connection is saved:
- Open the connection and navigate to the Functions tab
- Click New Function to open the function type selection dialog
- Choose a Read function (FC01-FC04) or a Write function (FC05-FC06, FC15-FC16)
- Fill in the Basic tab (name, description, labels) and the Configuration tab (addresses, values)
- Use the Test button to validate the function before saving
Each function has two configuration tabs:
- Basic: Function name (required, max 100 characters, must be unique within the connection), optional description, and labels
- Configuration: Function-specific parameters (address, quantity, values, data type)
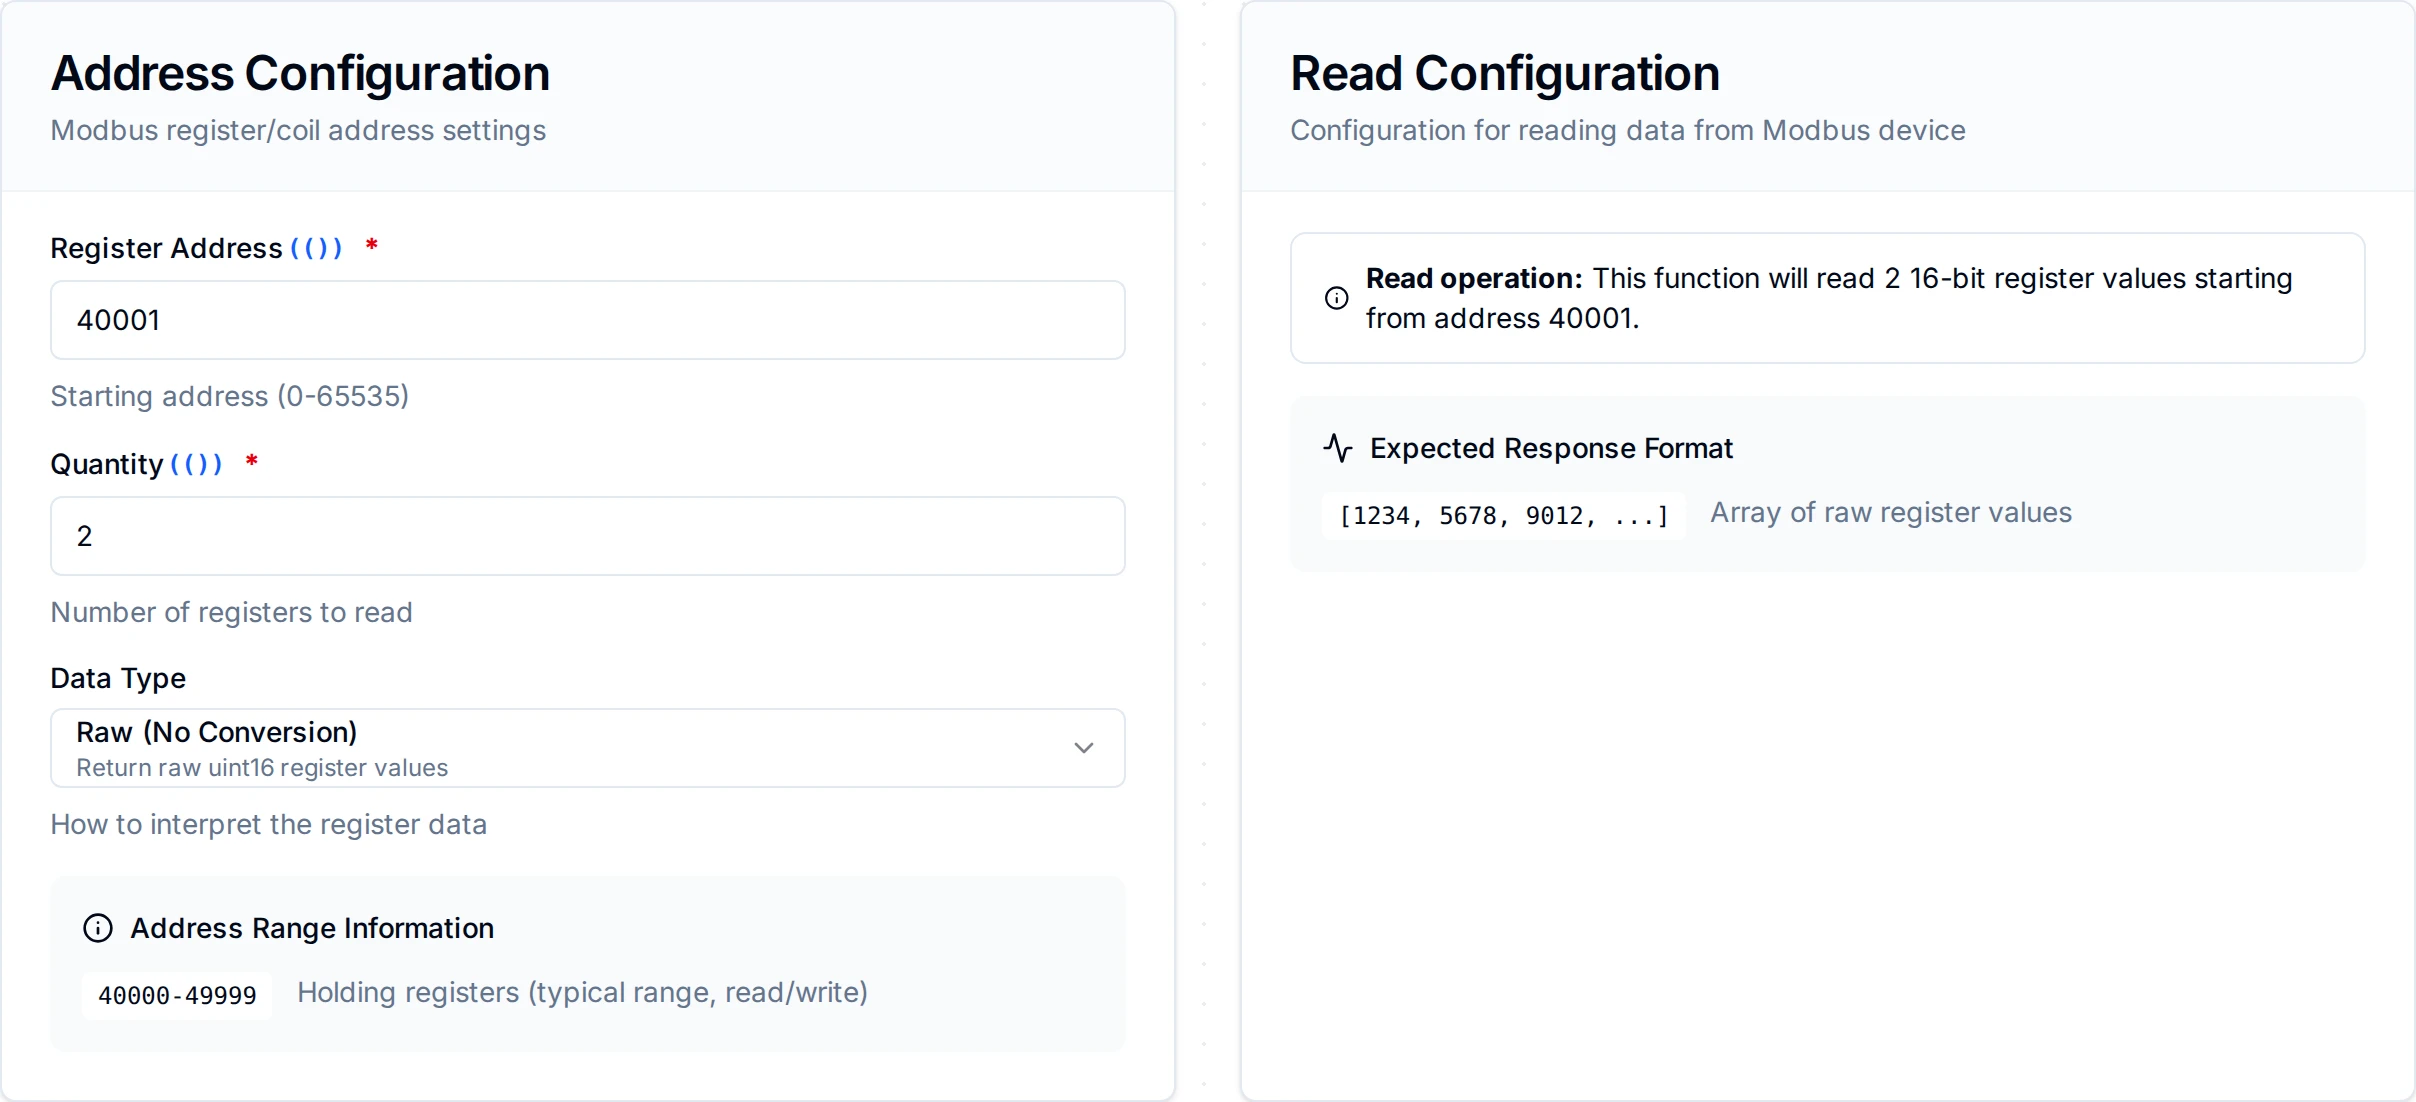
A read function: register address, quantity and how to interpret the registers
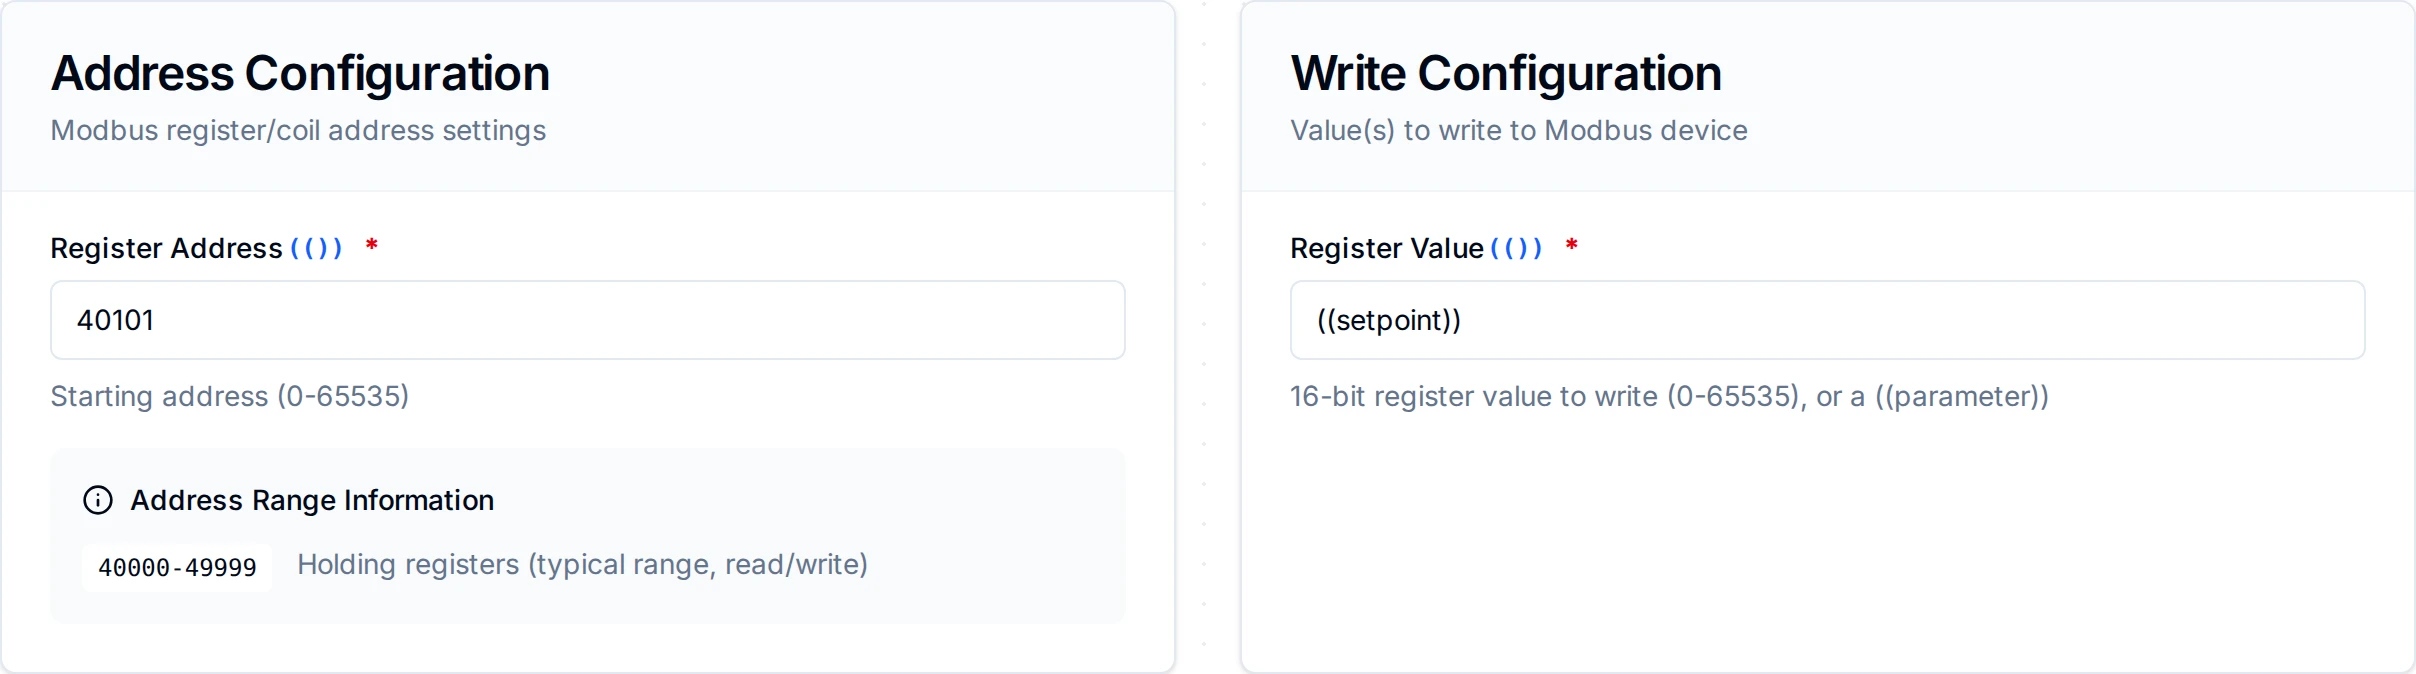
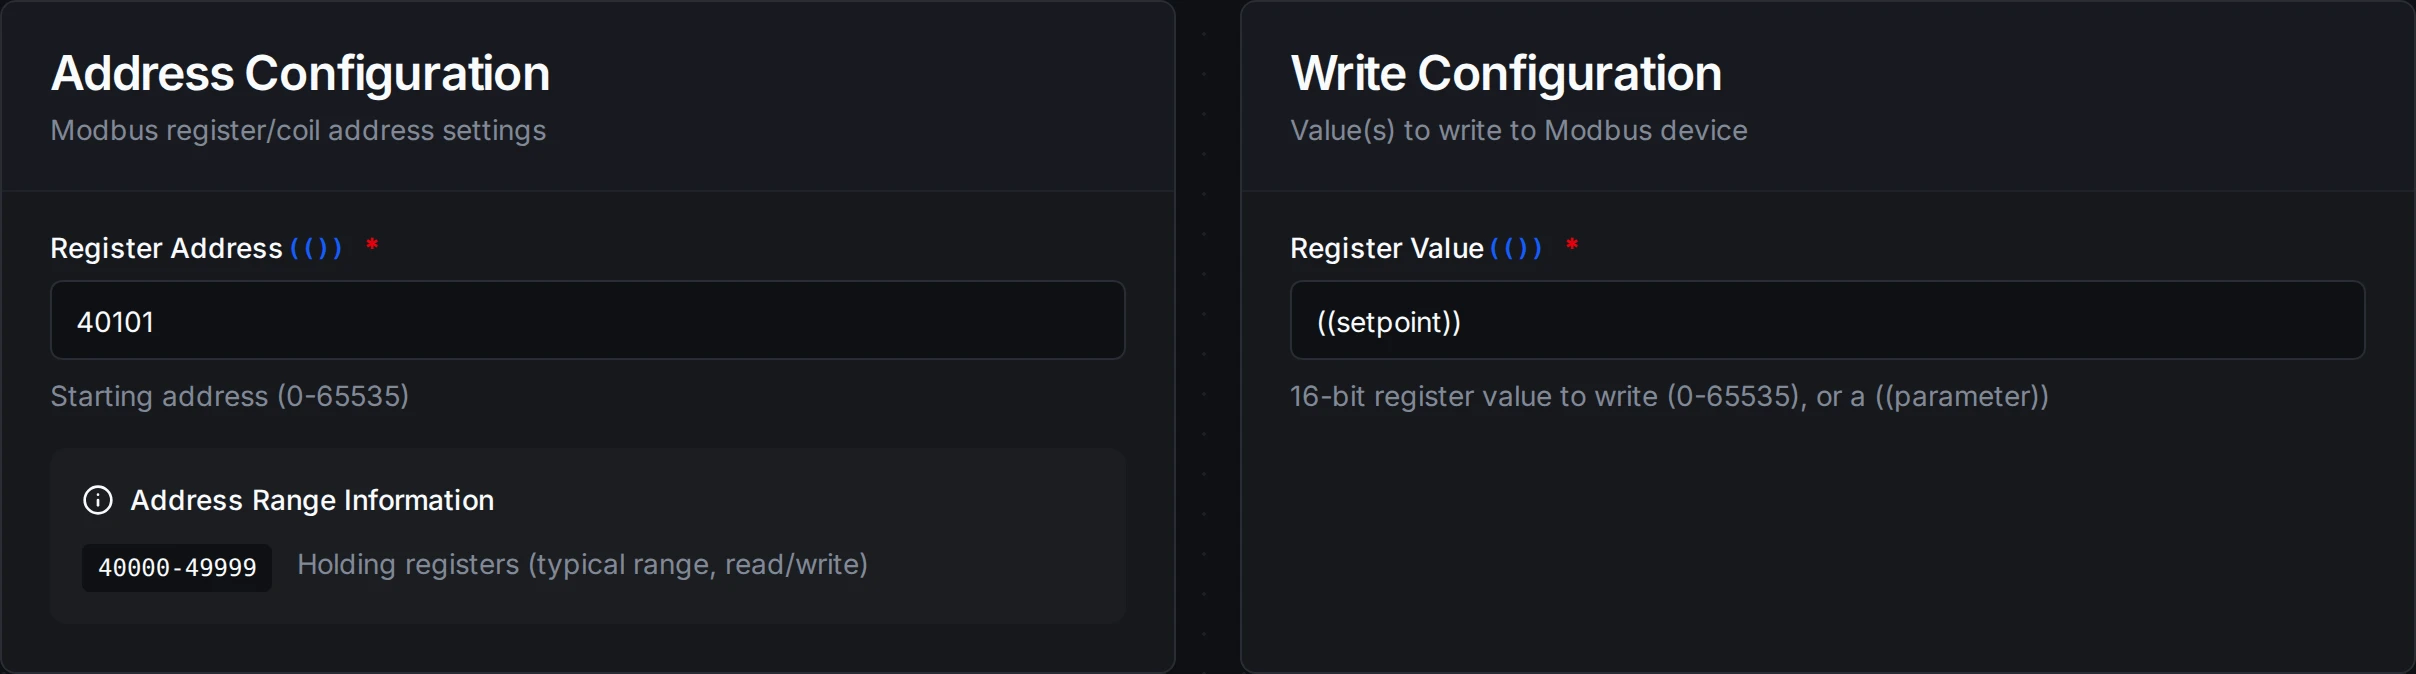
A write function: the register address and the value, here a ((setpoint)) parameter
Quick Add: Bulk Function Creation
For scenarios where you need to create multiple Modbus functions at once, the Quick Add feature streamlines the process by allowing you to define many functions in a single operation.
When to Use Quick Add
- Setting up a new Modbus connection with dozens of tags to monitor
- Migrating existing tag lists from spreadsheets or documentation
- Standardizing function creation across multiple similar devices
- Quickly prototyping data collection without creating functions one by one
How to Use Quick Add
- Navigate to your Modbus connection in Connections
- Click Quick Add Functions button
- Choose your input method:
- Table Entry: Add rows directly in the interface
- CSV Import: Upload a CSV file with function definitions
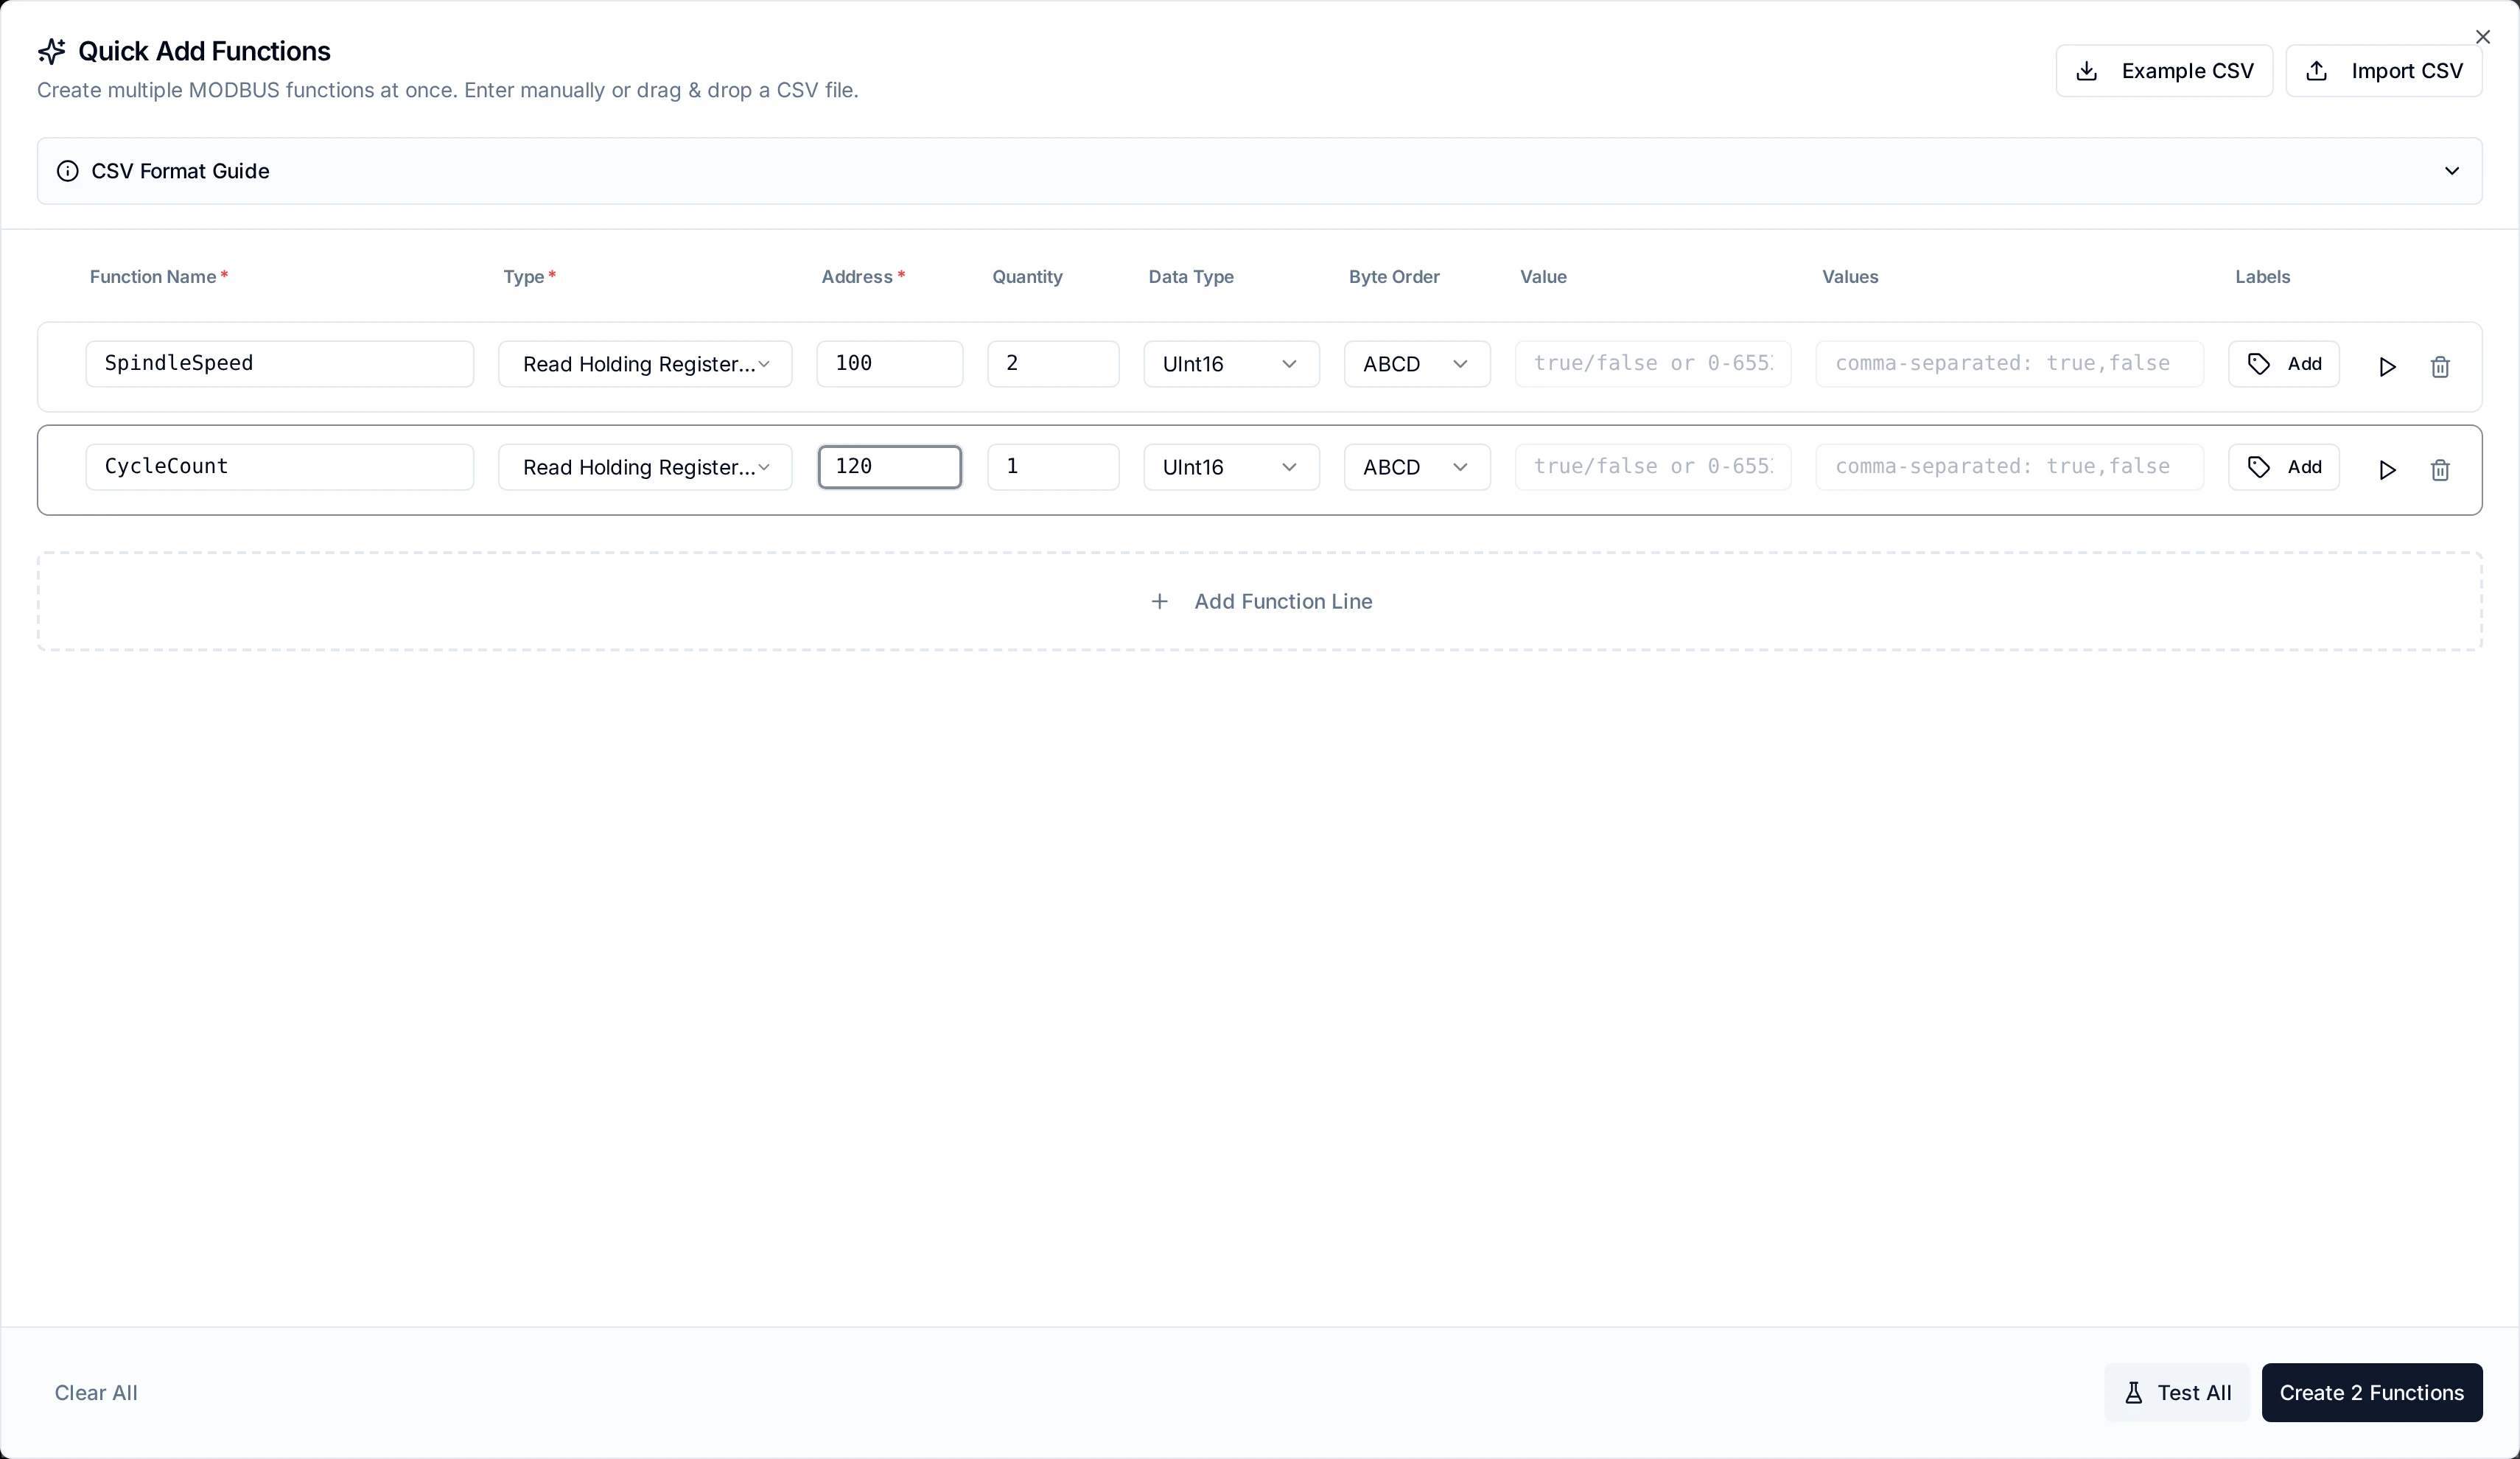
Quick Add Functions dialog with table entry and CSV import options
Table Columns
The Quick Add table enables and disables columns based on the function code so you only fill in the fields that function actually uses.
| Column | Applies to | Description | Example |
|---|---|---|---|
| Function Name | All FCs | Unique name for the function | Temperature_Sensor_1 |
| Type | All FCs | Modbus function code | Read Holding Registers (FC03) |
| Address | All FCs | Starting register/coil address (0-65,535) | 40001 |
| Quantity | Reads only | Number of registers/coils to read. Disabled for writes (single = 1 implicit, multi = derived from the Values cell). | 1 |
| Data Type | Holding/Input register reads only | Value interpretation. Disabled (and ignored) for coil/discrete reads and all writes. | float32, uint16, int32 |
| Byte Order | Holding/Input register reads with a numeric data type | How the device stores the number across its registers (see Byte Order). Defaults to ABCD; ignored for raw, bool, string, hex and bits. | ABCD, CDAB |
| Value | Single writes (FC05, FC06) | The value to write. Coils accept true/false/on/off/yes/no/1/0; registers accept decimal 0–65535 or 0xHEX. | true, 1500, 0x00FF |
| Values | Multi writes (FC15, FC16) | Comma- or whitespace-separated list of values. Same per-value rules as the Value column. | true,false,true,true, 100,200,300 |
| Labels | Optional, all FCs | Per-function tags for filtering and grouping. Click the Labels button to edit; the badge shows the current count. In CSV use key=value;key=value. Up to 10 labels per function. | area=motors;team=automation |
Supported Function Types in Quick Add
- Read Coils (FC01)
- Read Discrete Inputs (FC02)
- Read Holding Registers (FC03)
- Read Input Registers (FC04)
- Write Single Coil (FC05)
- Write Single Register (FC06)
- Write Multiple Coils (FC15)
- Write Multiple Registers (FC16)
CSV Import Format
The CSV mirrors the table columns. Leave a cell empty when the function code doesn't use it (e.g. no dataType for coil reads, no value for read functions). Quote any cell that contains commas, used for the multi-write values column.
The labels column is optional. Pairs are separated by ; and each pair uses key=value. The first = per pair is the delimiter so values can contain =. Whitespace around = and ; is tolerated. Label values cannot contain a literal ; in CSV; use the popover editor when you need that.
name,functionType,address,quantity,dataType,byteOrder,value,values,labels
Temperature,read.holdingRegisters,40001,1,float32,ABCD,,,area=process;env=prod
FlowRate,read.holdingRegisters,40010,2,uint32,ABCD,,,area=process
EnergyMeterKWh,read.holdingRegisters,40024,1,uint32,CDAB,,,area=energy
RawBlock,read.holdingRegisters,40100,8,raw,,,,
SetpointReg,read.inputRegisters,30005,1,uint16,,,,
RelayBank,read.coils,0,8,,,,,area=relays
DoorSensors,read.discreteInputs,10000,16,,,,,team=facilities
EnableRelay,write.singleCoil,5,,,,true,,team=automation
SetSpeed,write.singleRegister,40020,,,,1500,,team=automation;priority=high
StartupRelays,write.multipleCoils,10,,,,,"true,false,true,true",team=automation
ParamBlock,write.multipleRegisters,40050,,,,,"100,200,300,400",team=automation
Validation Rules
- Function names must be unique within the connection.
- Addresses must be in range 0-65,535.
- Read operations: quantity must be at least 1, and within the per-FC cap enforced by the backend:
- Read Coils / Read Discrete Inputs: 2,000 max
- Read Holding Registers / Read Input Registers: 125 max (further constrained by data type width; see below)
- Multi-byte data types use multiple registers: total registers (quantity × data type register count) cannot exceed 125 for register reads.
- Example: 50 ×
float32(2 regs each) = 100 registers ✓, 32 ×uint64(4 regs each) = 128 > 125 ✗
- Example: 50 ×
- Write operations:
- Single writes (FC05, FC06): Value is required.
- Write Multiple Coils (FC15): at least 1 and at most 1,968 boolean values.
- Write Multiple Registers (FC16): at least 1 and at most 123 uint16 values.
Best Practices
- Use descriptive function names that reflect the physical sensor or control point
- Group related functions together using consistent naming (e.g.,
Tank1_Temperature,Tank1_Pressure) - Validate your CSV file with a small batch before importing hundreds of functions
- Consider data type register counts when planning bulk reads to stay within the 125 register limit
Data Types
Modbus register data can be interpreted using the following data types. The data type determines how raw 16-bit register values are converted into meaningful values.
| Data Type | Registers | Description |
|---|---|---|
raw | Variable | No conversion: returns array of raw 16-bit unsigned values |
bool | 1 | Single bit/coil value (true/false) |
int16 | 1 | Signed 16-bit integer (−32,768 to 32,767) |
uint16 | 1 | Unsigned 16-bit integer (0 to 65,535) |
int32 | 2 | Signed 32-bit integer |
uint32 | 2 | Unsigned 32-bit integer |
float32 | 2 | IEEE 754 single-precision floating point |
int64 | 4 | Signed 64-bit integer |
uint64 | 4 | Unsigned 64-bit integer |
float64 | 4 | IEEE 754 double-precision floating point |
string | Variable | ASCII text (2 characters per register, null-terminated) |
hex | Variable | Hexadecimal string representation (e.g., FF00 00A1) |
bits | Variable | Bit array: 16 bits per register, MSB first |
When reading multi-register data types, set the Quantity field to match the register count. For example, reading a float32 value requires a quantity of at least 2 registers, and float64 requires 4.
Byte Order
Devices differ in how they lay a number's bytes across 16-bit registers, and the data cannot tell you which layout a device uses. Set Byte Order on each register read to match the device manual. It applies to the numeric data types (int16 to float64); raw, bool, string, hex and bits read registers as they arrive.
The letters name where the bytes of a 32-bit value (A is the most significant) end up. For example, the value 3099 (0x00000C1B) in two registers:
| Byte Order | Layout | First register | Second register | Typical devices |
|---|---|---|---|---|
ABCD (default) | Big-endian: high word first, high byte first | 0x0000 | 0x0C1B | The Modbus convention; most devices |
CDAB | Word swap: low word first | 0x0C1B | 0x0000 | Many PLCs and energy meters (Modicon convention) |
BADC | Byte swap inside each register | 0x0000 | 0x1B0C | Some gateways and older devices |
DCBA | Little-endian: low word first, bytes swapped | 0x1B0C | 0x0000 | Devices that send memory as-is |
For 64-bit types, CDAB and DCBA reverse the order of all four registers. result.registers always shows the registers as the device sent them, and result.byteOrder shows the order used to decode result.value.
Reading the example above with ABCD from a CDAB device returns 203,096,064 instead of 3099, with no error. If a value looks scaled by about 65,536 or is far out of range, check the byte order before anything else.
Read Coils (modbus.read.coils)
Purpose: Read status of discrete outputs (coils) using Function Code 01. Coils can be either ON (true) or OFF (false), allowing reading of multiple coil states in a single operation.
Configuration Fields
| Field | Type | Required | Default | Description |
|---|---|---|---|---|
| Starting Address | Number | Yes | 0 | First coil address to read (0-65,535) |
| Quantity | Number | Yes | 1 | Number of coils to read in sequence (1-2,000) |
Use Cases: Read relay states, check digital outputs, monitor coil status, bulk coil reading
Read Discrete Inputs (modbus.read.discreteInputs)
Purpose: Read status of discrete inputs using Function Code 02. These are typically read-only digital inputs from sensors, switches, or other devices.
Configuration Fields
| Field | Type | Required | Default | Description |
|---|---|---|---|---|
| Starting Address | Number | Yes | 10000 | First discrete input address to read (0-65,535) |
| Quantity | Number | Yes | 8 | Number of discrete inputs to read (1-2,000) |
Use Cases: Read sensor states, monitor switch positions, check digital inputs, bulk input scanning
Read Holding Registers (modbus.read.holdingRegisters)
Purpose: Read values from holding registers using Function Code 03. These are read-write 16-bit registers used for configuration, setpoints, and other operational data. This is the most common Modbus operation.
Configuration Fields
| Field | Type | Required | Default | Description |
|---|---|---|---|---|
| Starting Address | Number | Yes | 40001 | First holding register address to read (0-65,535) |
| Quantity | Number | Yes | 10 | Number of registers to read (1-125) |
| Data Type | Select | No | raw | Data type for value conversion (see Data Types table) |
| Byte Order | Select | No | ABCD | How the device stores numbers across registers (see Byte Order); shown for numeric data types |
Use Cases: Read setpoints, get configuration values, monitor process variables, bulk data acquisition
Read Input Registers (modbus.read.inputRegisters)
Purpose: Read values from input registers using Function Code 04. These are typically read-only 16-bit registers containing measurement data, sensor readings, and status information.
Configuration Fields
| Field | Type | Required | Default | Description |
|---|---|---|---|---|
| Starting Address | Number | Yes | 30001 | First input register address to read (0-65,535) |
| Quantity | Number | Yes | 4 | Number of registers to read (1-125) |
| Data Type | Select | No | raw | Data type for value conversion (see Data Types table) |
| Byte Order | Select | No | ABCD | How the device stores numbers across registers (see Byte Order); shown for numeric data types |
Use Cases: Read sensor values, get measurement data, monitor input signals, data logging operations
Write Single Coil (modbus.write.singleCoil)
Purpose: Write a single coil (discrete output) to ON or OFF state using Function Code 05. Used for controlling individual relays, digital outputs, or other binary actuators.
Configuration Fields
| Field | Type | Required | Default | Description |
|---|---|---|---|---|
| Coil Address | Number | Yes | 0 | Address of the coil to write (0-65,535) |
| Coil Value | Boolean | Yes | true | State to write to the coil (true = ON, false = OFF). Supports parameter templates. |
Use Cases: Control relay states, set digital outputs, toggle equipment on/off, actuator control
Write Single Register (modbus.write.singleRegister)
Purpose: Write a single 16-bit value to a holding register using Function Code 06. Used for setting configuration values, setpoints, and other control parameters.
Configuration Fields
| Field | Type | Required | Default | Description |
|---|---|---|---|---|
| Register Address | Number | Yes | 40001 | Address of the register to write (0-65,535) |
| Register Value | Number | Yes | 0 | 16-bit value to write (0-65,535). Supports parameter templates. |
Use Cases: Set configuration values, update setpoints, write control parameters, individual register updates
Write Multiple Coils (modbus.write.multipleCoils)
Purpose: Write multiple coils (discrete outputs) in a single operation using Function Code 15. Allows efficient bulk control of relays, digital outputs, or other binary devices.
Configuration Fields
| Field | Type | Required | Default | Description |
|---|---|---|---|---|
| Starting Address | Number | Yes | 0 | First coil address to write (0-65,535) |
| Coil Values | Array | Yes | [true, false] | Array of boolean values for each coil (1-1,968 coils). Supports parameter templates. |
Use Cases: Control multiple relays, set digital output patterns, bulk coil updates, equipment sequences
Write Multiple Registers (modbus.write.multipleRegisters)
Purpose: Write multiple 16-bit values to consecutive holding registers using Function Code 16. Allows efficient bulk updates of configuration data, setpoints, and control parameters.
Configuration Fields
| Field | Type | Required | Default | Description |
|---|---|---|---|---|
| Starting Address | Number | Yes | 40001 | First register address to write (0-65,535) |
| Register Values | Array | Yes | [0, 0] | Array of 16-bit values for consecutive registers (1-123 registers, each 0-65,535). Supports parameter templates. |
Use Cases: Bulk configuration updates, set multiple setpoints, write parameter blocks, data download operations
Using Parameters
Parameter placeholders ((parameterName)) can be used in write function fields (value, values, address) to make functions dynamic at execution time.
MaestroHub detects the placeholders when you save the function and stores each one as a parameter of type any, optional, with no default value. Unlike most connectors, the Modbus function form has no Function Parameters panel, so you cannot set a type, required flag, default or description on these parameters. Validate the values upstream in the pipeline, for example in the node that builds them.
Testing Functions
Every Modbus function can be tested before saving using the built-in Test dialog:
- Click the Test button in the function form
- The dialog shows an Execution Overview with the current configuration
- Override any parameter values in the Test Parameters section
- Click Execute Test to run the function against the live device
- View the result in the integrated JSON viewer, including execution duration and timestamp
The test dialog supports two modes:
- Config-only Testing (create mode): Tests the function configuration before saving
- Function with Overrides (edit mode): Tests the saved function with current form modifications
Pipeline Integration
Use the Modbus connection functions you define here as nodes inside the Pipeline Designer to synchronize PLC registers with the rest of your pipeline. Drag in the read or write node, bind parameters to upstream outputs or constants, and set retries or guard conditions before issuing commands.
For orchestration strategies that mix Modbus with other data sources, check the Nodes page to see how these nodes slot into larger automation flows.
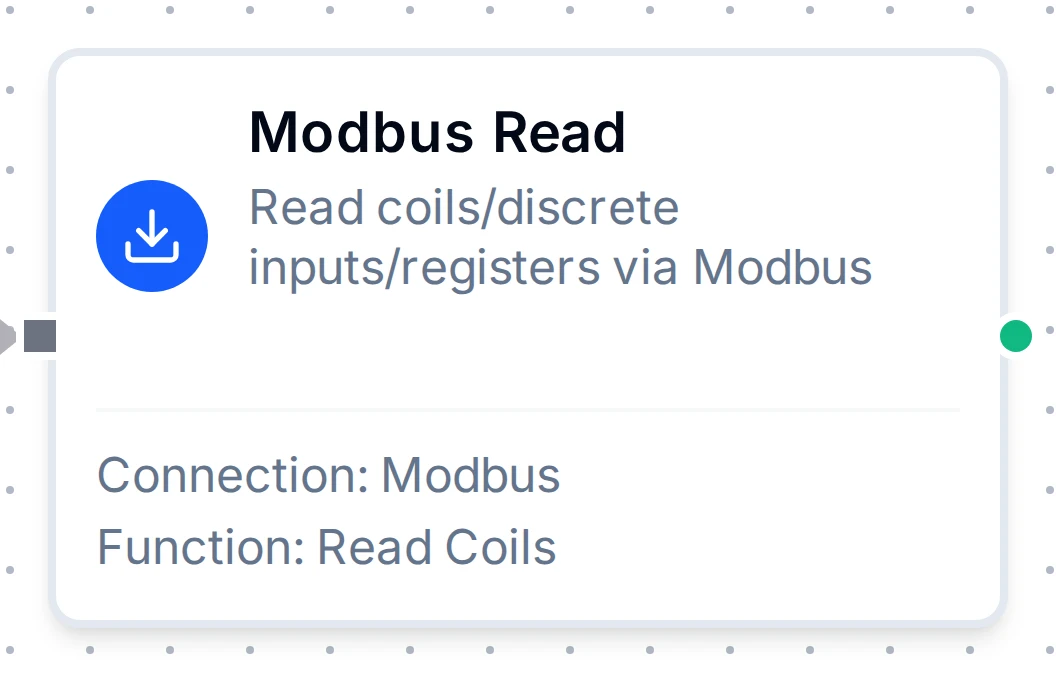
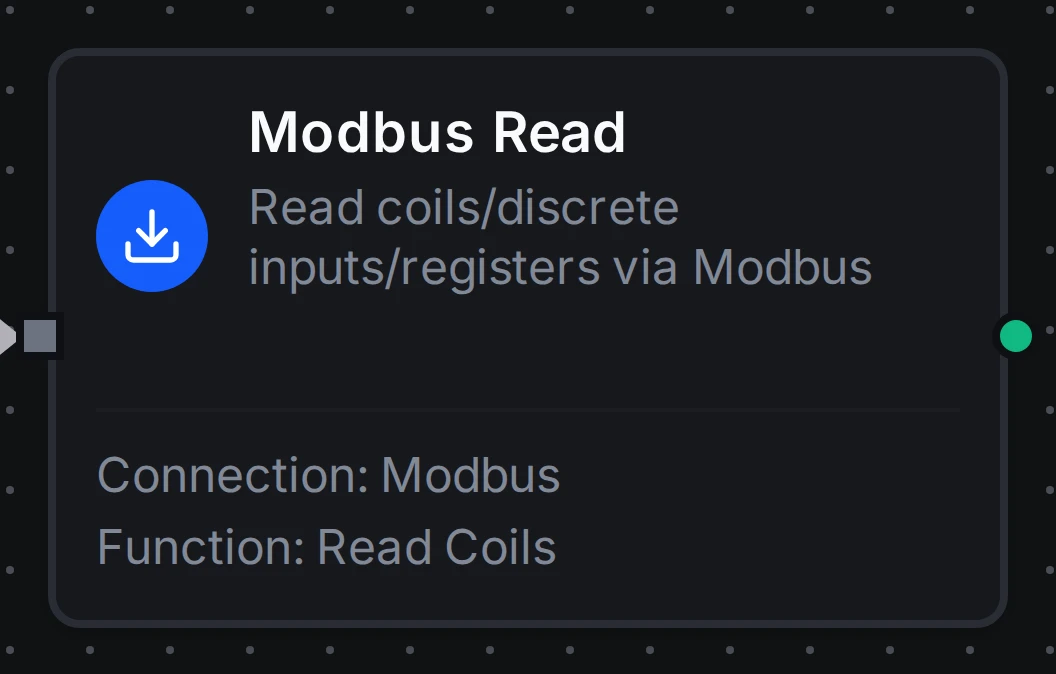
Modbus read node with connection, function, and parameter bindings
Common Use Cases
Equipment Monitoring
Poll holding and input registers for temperature, flow, vibration, or energy metrics, then forward the data to historians or MQTT topics.
Control and Setpoint Management
Validate operator inputs and write them back to coils or registers to adjust production processes safely.
Data Normalization
Convert raw register values into engineering units, status codes, or structured JSON for downstream analytics using the built-in data type conversions (float32, int32, etc.).
Many slaves behind one gateway
A Modbus TCP to serial gateway (for example an RS-485 gateway in front of a line of meters) has one serial bus behind it, and the bus carries one request at a time. MaestroHub has one connection per slave, so a site with 30 slaves has 30 connections to the same gateway address.
How MaestroHub shares a gateway
- Connections to the same address take turns. Only one request is on the wire to a gateway at a time; the others wait in MaestroHub. The Request Timeout counts from the moment a request is sent, so a slave that answers promptly does not time out because its turn came late. A request that waits longer than the Request Timeout for its turn fails with gateway ... is saturated, and the message says how many connections share the gateway and which unit ids they are.
- A slave that does not answer does not hold the others up. After about three normal exchange times, the next request is sent and queues at the gateway, which moves on when its own slave timeout expires.
- A slow reply is not a lost connection. A reply that comes after the Request Timeout is recognised by its transaction id and dropped, so it never becomes the value of another read. The connection stays open.
- A slave that never answers still reconnects. When a gateway sends nothing at all for an absent slave, three requests in a row with no reply look the same as a broken network path, so the connection is closed and opened again. If the gateway answered another slave meanwhile, the error says slave N is not answering so you know to check that slave rather than the network.
Connections count as the same gateway when their Address is written the same way: 10.0.0.5:502 and gateway-1:502 are treated as two gateways even if they are the same device. Use one spelling for every slave behind a gateway.
A gateway with several serial ports behind one address (each port a separate bus, routed by unit id) can answer one request per port at a time. Set Gateway Serial Port on each connection to the port its slave is wired to, for example 1 or 2: connections then take turns per port instead of across the whole gateway.
Where to see it
On Connection Health, each connection's Failing operations tile shows how many operations failed and its most frequent failure message (hover it for the full text). These messages read the same every time they repeat, so they count as one problem: a saturated gateway shows as gateway 10.0.0.5:502 is saturated ... 30 connections share it (units 1-30) and an absent slave as slave 30 is not answering, on the connections they affect.
Is the bus big enough?
A serial bus has a fixed capacity. One exchange takes roughly:
time per read = (request bytes + reply bytes) x 11 bits / baud rate + the slave's reply delay
request bytes = 8
reply bytes   = 5 + 2 x registers read
At 9600 baud, reading 60 holding registers takes about 0.15 s, so 30 slaves need about 4.6 s for one round of reads. Polling each of them every second is more than the bus can carry: reads queue up and fail with gateway ... is saturated. Every slave that does not answer adds the gateway's own slave timeout to each round.
Settings to check on the gateway and in MaestroHub
| Setting | Recommendation |
|---|---|
| Gateway slave timeout | Set it below MaestroHub's Request Timeout (for example 1 s with a 5 s Request Timeout), so the gateway gives up on an absent slave before MaestroHub does. |
| Reply for an absent slave | If the gateway can answer with exception 0x0B (gateway target device failed to respond), turn it on. The connection then stays up and only the reads for that slave fail. |
| Maximum TCP connections | Make sure the gateway accepts at least one connection per slave you configure, plus any other masters (SCADA, engineering tools). |
| Poll load | Poll less often, read fewer registers, or merge reads with Read Groups (Section 5c) until one round of reads fits in the poll interval. |
| Bus speed and layout | Raise the bus baud rate if every slave supports it, or split the slaves across several gateways or serial ports. |
Troubleshooting
Connection Issues
| Symptom | Possible Cause | Solution |
|---|---|---|
| Connection timeout | Device not reachable | Verify network connectivity, IP address, and port. Standard Modbus TCP port is 502. |
| Invalid address format | Malformed host:port | Ensure address is in host:port format (e.g., 192.168.1.10:502). Port must be 1-65,535. |
| Serial port error | Wrong device path | Verify the serial device path (/dev/ttyUSB0, COM3, etc.) and that the port is not in use. |
| Unit ID mismatch | Wrong slave address | Confirm the Unit ID matches the device's configured slave address (0-247). |
| Health check fails | Device unresponsive | Check the health check method and register settings. Try switching to Status method first. |
| gateway ... is saturated | More reads than the gateway's serial bus can carry | See Many slaves behind one gateway: poll less often or fewer registers, or split the slaves across gateways. |
| slave N is not answering, then a reconnect | That slave is off, unwired, or has another unit id, behind a gateway that sends no reply for it | Check the slave. Set the gateway to reply with exception 0x0B for an absent slave so the connection stays up. |
Function Issues
| Symptom | Possible Cause | Solution |
|---|---|---|
| Illegal function error | Unsupported function code | Verify the device supports the requested function code (e.g., not all devices support FC15/FC16). |
| Illegal data address | Address out of range | Check that the starting address and quantity don't exceed the device's address space. |
| Read Group: every function returns "illegal data address" in parallel mode but works in sequential mode | Coalescing is including unmapped registers in the merged request | Lower Coalesce Max Register Gap on the connection (Section 5c) to a value the slave accepts, or set it to 0 for safe per-function reads. |
| Incorrect values | Wrong data type | Ensure the data type matches the device's register format (e.g., float32 for IEEE 754 values). |
| Register limit exceeded | Too many registers | Reduce quantity: maximum is 125 for register reads and 2,000 for coil/discrete reads. |
| Timeout on write | Device busy | Increase the request timeout or add retry logic. Check if the device is in a protected mode. |
Use the Test button in the Function Builder to validate your configuration before using it in pipelines. The test dialog lets you override parameters for one-off operations and displays the full response with execution timing.
Poll trigger quality
Every poll delivery carries _metadata.quality. A successful read is good, because Modbus has no per-value status, so the read outcome is the device's statement. When a read fails (a Modbus exception such as server device failure, or a dead socket), the poll fires once per outage with quality: "bad", the driver's error text under _metadata.error, and the last successfully read payload as result (or the register's identity, when nothing was ever read). It does not fire again until the next successful read, which is good as before. A UNS Publish node downstream inherits the verdict automatically, so the historian marks the moment the device went dark instead of seeing silence.